Touch Screens Behind Thick Glass and Protective Windows: What Works and What Does Not
Thick-glass touch: compare sensor placements by effective coupling distance, see where each option stops working, and the evidence to request.
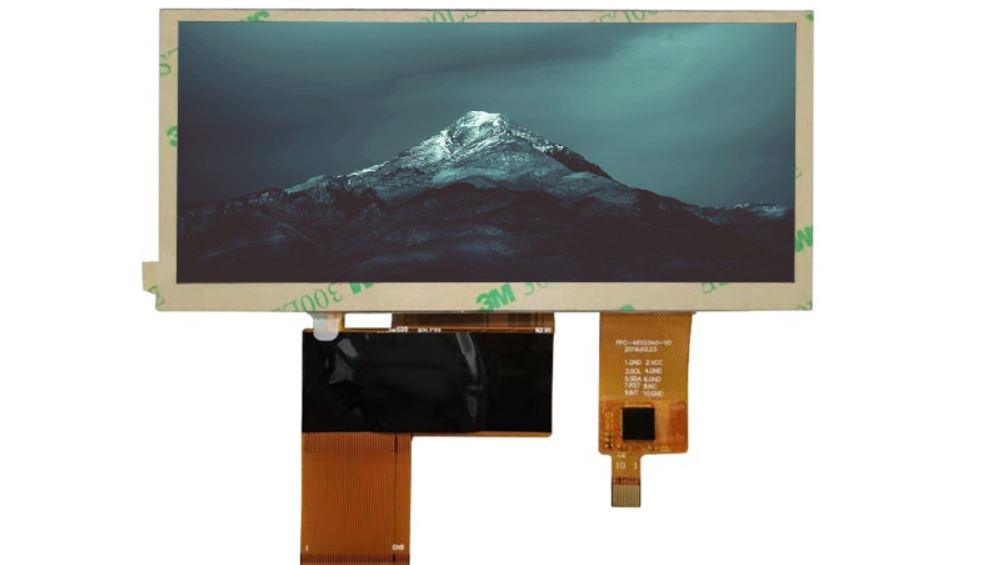
Putting the touch sensor behind a protective window is a common requirement in public, industrial and outdoor equipment, and it works well within limits. Beyond those limits it produces a screen that works with a bare finger on a good day and fails with gloves, rain or cold hands. The useful engineering question is how much thickness the design can afford, and what changes when the answer is “not enough”.
Part of the Custom Displays, Sourcing & Manufacturing guide — 46 articles on tooling, sampling, MOQ and supply-chain risk.
Last updated:
How much thickness capacitance can tolerate
Every millimetre reduces the measured signal.
The coupling change produced by a finger falls as the distance between the finger and the sensor electrodes increases, and the relationship is steep enough that the difference between 2 mm and 6 mm of glass is substantial. Bonding the sensor to the display rather than to the outer glass adds further distance. As a rule of thumb, thin protective windows of a few millimetres are achievable with careful design, while very thick windows require either a sensor placed closer to the touch surface or a different sensing technology.
The practical approach is to measure rather than estimate. A grid test on the actual stack, with the actual glove and water conditions, gives the pass rate at each point, which is the number that decides whether the design is viable. CDTech’s notes on touch controller selection and tuning describe the parameters that can be adjusted once the stack is fixed.
Sensor placement options and their consequences
Four configurations, four cost and performance profiles.
| Configuration | Sensing distance | Trade-off |
|---|---|---|
| Sensor on the outer glass (on-lens) | Shortest | Most expensive; complex cover glass; best sensitivity |
| Sensor on a separate layer bonded behind the outer glass | Outer glass thickness | Balanced; extra lamination step |
| Sensor integrated in the display module | Outer glass plus bonding | Cheapest at scale; least sensitivity |
| Sensor on a film applied behind the window | Outer glass plus film | Flexible for retrofits; film adds optical loss |
For public installations, the on-lens or separate-layer options are usually chosen because the outer glass is thick, while for industrial equipment with a thinner front the module-integrated sensor is often sufficient. The decision is essentially about where in the stack the money buys the most sensitivity.
Floating windows and bonding as an electrical decision
A protective window is part of the circuit.
A window that is not bonded to the display can be electrically floating, which makes its effect on the sensor unpredictable and dependent on how it is mounted. Bonding the window to the sensor layer, or providing a defined conductive path, stabilises the dielectric stack and makes tuning repeatable. Where the window must remain removable, the design should define how it is referenced – for example through a conductive gasket or a defined air gap – and validate touch performance with the window fitted, not on the bare assembly.
This is one of the most common sources of “works in the lab, fails in the field” behaviour, because the prototype window and the production window differ in thickness, coating or mounting.
Controller features that extend the working range
Some controllers are built for exactly this problem.
Controllers intended for thick-glass and glove applications offer higher drive voltage, more sensitive front ends, better noise rejection and adaptive baseline tracking. Choosing one of these extends the achievable thickness, at the cost of more careful layout to avoid emissions and more attention to the sensor pattern. Where even that is insufficient, the remaining options are to thin the glass in the touch area, to reduce the touch-sensitive region to a smaller zone with thinner glass, or to abandon capacitive sensing for that surface.
The selection should be made with the thickness target in view, since the controller is the largest single lever on achievable performance.
Where the approach stops working
Four conditions that usually end the discussion.
- Thick glass combined with thick gloves: the two losses compound rather than add independently.
- Laminated safety glass with an interlayer that is electrically lossy or inconsistent.
- A window that cannot be bonded and is not reliably referenced, making performance depend on assembly variation.
- A requirement for use in heavy rain while also detecting a gloved finger, since the tuning for one degrades the other.
When these appear together, physical controls, a resistive touch layer, or an indirect input such as a mobile interface are usually the better answers. Recognising this at specification stage saves a project from a design that is permanently marginal.
Where Should the Sensor Sit in the Stack?
The distance from the finger to the sensor electrodes — not the cover-glass thickness on its own — is what sets the signal, so placing the sensor differently in the same stack can change the coupling by a factor of five. That is why two displays with identical 6 mm glass behave completely differently.
Model with stated assumptions: effective separation is the sum of the layers between the finger and the electrodes, and relative signal falls roughly as 1/d against a 1 mm reference (the second column is the modelled separation in millimetres, the third the resulting relative signal). Adhesives, air gaps and any shielding layer each add to that distance, so the numbers are an order-of-magnitude guide for comparing placements rather than a measurement of a specific module.
| Sensor placement | Modelled separation (mm) | Relative signal (1 mm = 1.00) | Practical consequence |
|---|---|---|---|
| On-lens (sensor on the front surface or the lens itself) | 0 – 1 | 1.00 | Highest signal; needs a lens-level process and protection for the sensor layer |
| Laminated to the rear of the cover glass | 1 – 3 | 0.67 – 0.50 | Good compromise when optical bonding is already required |
| Behind an air gap or a floating window | 4 – 8 | 0.33 – 0.20 | Workable for large targets; water films and gloves fail first |
| Behind the LCD cell | 10+ | 0.20 – 0.10 | Only for coarse input; the cell and its shielding consume most of the coupling |
The table explains the classic field failure: a design validated with the sensor laminated to the cover glass is re-quoted with an air gap to save cost, and the same firmware that passed on the bench becomes marginal. It also shows why a floating window is an electrical decision before it is a mechanical one — if the window cannot be bonded, the sensor has to move forward or the controller has to be chosen for the extra distance.
What to ask for as evidence. Request a stack drawing that names every layer between the finger and the electrodes with its thickness, the measured capacitance of the finished sensor, the controller sensitivity quoted at that capacitance, and the validation grid results for the stack as built (not as drawn). Optical and structural customisation covers the bonding and cover-lens work that keeps the sensor close to the touch surface.
Validation that predicts field behaviour
Test the production stack in the production mounting.
- Build the full stack: outer window, adhesive or gap, sensor layer, display.
- Mount it in the production bezel or frame, with the gasket or bonding as intended.
- Run a grid test including the outer 10 mm, with bare fingers, each glove type and a wet surface.
- Repeat at the temperature extremes and at the brightness levels used in service.
- Repeat with noise aggressors operating, such as backlight and any nearby drives.
- Record the pass rate per condition, and keep the configuration with the results.
A test that omits the outer window or the mounting is not predictive, because those are exactly the elements that change the dielectric stack. Static-discharge behaviour of the same front should also be considered, with reference material from the EOS/ESD Association, and coating choices are measured with methods such as ASTM D1003.
Design patterns that work in practice
Three patterns cover most successful installations.
The first is a thin bonded front: a 1 to 3 mm strengthened glass bonded directly to the display with an integrated sensor, used where impact exposure is moderate and touch is frequent. The second is an on-lens sensor behind a thick outer window, used in public installations where the outer glass is 4 to 6 mm and a limited number of large touch targets are required. The third is a physical-control interface with a display behind a thick window, used where gloves are unavoidable and the display is primarily an output.
Choosing between them is a matter of matching the input requirement to the environment rather than of optimising the sensor specification, and the choice should be made before the enclosure is designed.
Cost comparison across the options
Sensitivity is bought with money and process complexity.
| Option | Relative cost | Best suited to |
|---|---|---|
| Thin bonded front, integrated sensor | Lowest | Industrial equipment, moderate impact, frequent touch |
| Separate sensor layer behind outer glass | Moderate | Public equipment with 3-5 mm windows |
| On-lens sensor with thick outer window | Highest | Vandal-prone installations, limited touch targets |
| Resistive layer or physical controls | Low to moderate | Heavy gloves, wet surfaces, primarily output displays |
In most projects the cheapest viable option is the correct one, provided the input requirements are validated with the actual gloves and environmental conditions rather than assumed from the datasheet.
FAQ
Can a capacitive touchscreen work through 10 mm of glass?
Only with a sensor placed close to the touch surface, such as an on-lens design, and typically only for bare-finger operation with large targets. At that thickness gloves and water films become very difficult, and a design that must support them is usually better served by resistive sensing or physical controls.
Why does touch work in the lab but fail in the field behind a protective window?
Because the window is part of the electrical stack, and the production window often differs from the prototype in thickness, coating or mounting. A floating window makes performance depend on assembly variation. Bond or reference the window deliberately, and validate with it fitted.
Where should the touch sensor sit in the stack?
As close to the touch surface as the budget allows. On-lens placement gives the best sensitivity at the highest cost, a separate bonded layer is a middle option, and a sensor integrated in the display module is the cheapest but the least sensitive through thick glass.
What alternatives exist when thick-glass touch is not viable?
Resistive sensing responds to pressure and tolerates gloves, water and thick windows at the cost of optical clarity and multi-touch. Physical controls beside an output-only display are often the most reliable answer for gloved, wet and heavy-duty environments.
Next step
Send the outer window thickness and material, mounting method, glove and water conditions and the touch targets required to CDTech; the reply will state what is achievable and where the sensor should sit in the stack.
Contact sales@cdtech-lcd.com or use the contact page.
Related articles
 Fuel Dispenser and Forecourt Displays: Safety, Sunlight and Continuous UseCustom Displays, Sourcing & Manufacturing
 Landed Cost for Display Modules: Freight, Duty, Packaging and the True Unit PriceCustom Displays, Sourcing & Manufacturing
 How to Audit a Display Factory: An Evidence-Based ChecklistCustom Displays, Sourcing & Manufacturing
 TFT LCD vs OLED vs E-Paper for Industrial Products: A 2026 Decision FrameworkCustom Displays, Sourcing & Manufacturing